Publications
A collection of my research work.
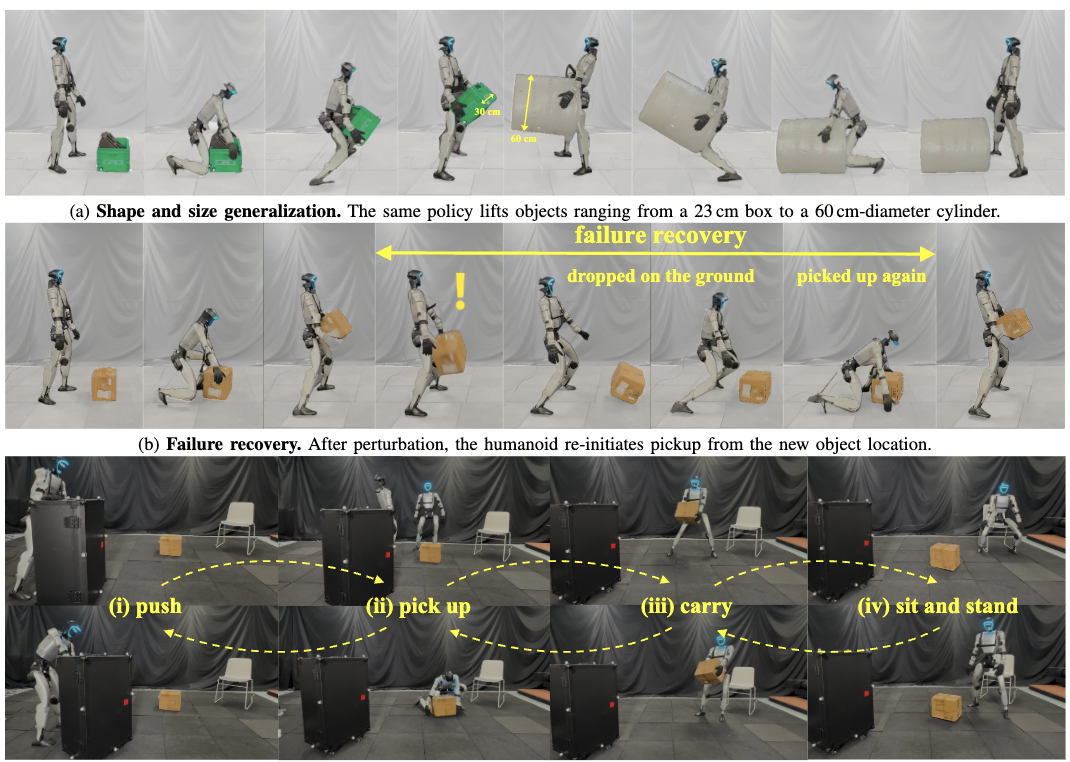
LessMimic: Long-Horizon Humanoid Interaction with Unified Distance Field Representations
Yutang Lin*, Jieming Cui*, Yixuan Li, Baoxiong Jia†, Yixin Zhu†, Siyuan Huang†
Neural Information Processing Systems (NeurIPS) 2026
LessMimic is a unified framework for humanoid-object interaction that learns directly from distance fields, enabling reference-free, geometrically-generalizable, and long-horizon skill composition.
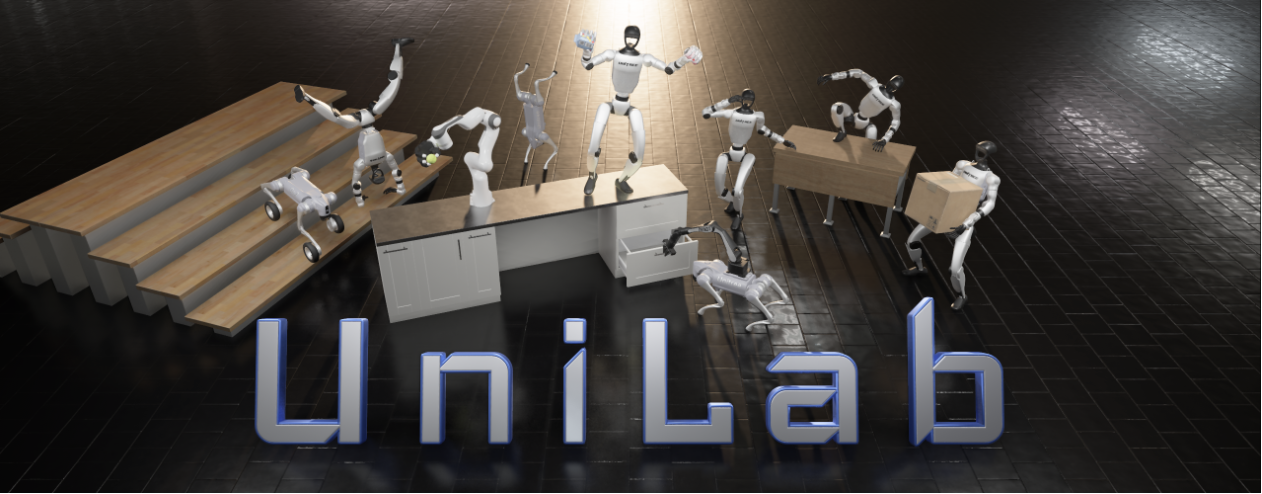
UniLab: A Heterogeneous Architecture for Robot RL Beyond GPU-Dominant Paradigms
Yufei Jia*, Zhanxiang Cao*, Mingrui Yu*, Heng Zhang*, Shenyu Chen*, Dixuan Jiang*, Meng Li, Xiaofan Li, Yiyang Liu, Junzhe Wu, Zheng Li, XiLin Fang, Tingyu Cui, Shengcheng Fu, Haoyang Li, Anqi Wang, Zifan Wang, Dongjie Zhu, Chenyu Cao, Zhenbiao Huang, Ziang Zheng, Jie Lu, Xin Ma, Zhengyang Wei, Xiang Zhao, Tianyue Zhan, Ye He, Yuxiang Chen, Yizhou Jiang, Yue Li, Haizhou Ge, Yuhang Dong, Fan Jia, Ziheng Zhang, Meng Zhang, Xiwa Deng, Zhixing Chen, Hanyang Shao, Chenxin Dong, Yixuan Li, Yizhi Chen, Bokui Chen, Kaifeng Zhang, Hanqing Cui, Yusen Qin, Ruqi Huang, Lei Han†, Tiancai Wang†, Xiang Li†, Yue Gao†, Guyue Zhou†
Conference on Robot Learning (CoRL) 2026
UniLab is configurable infrastructure for robot reinforcement learning.
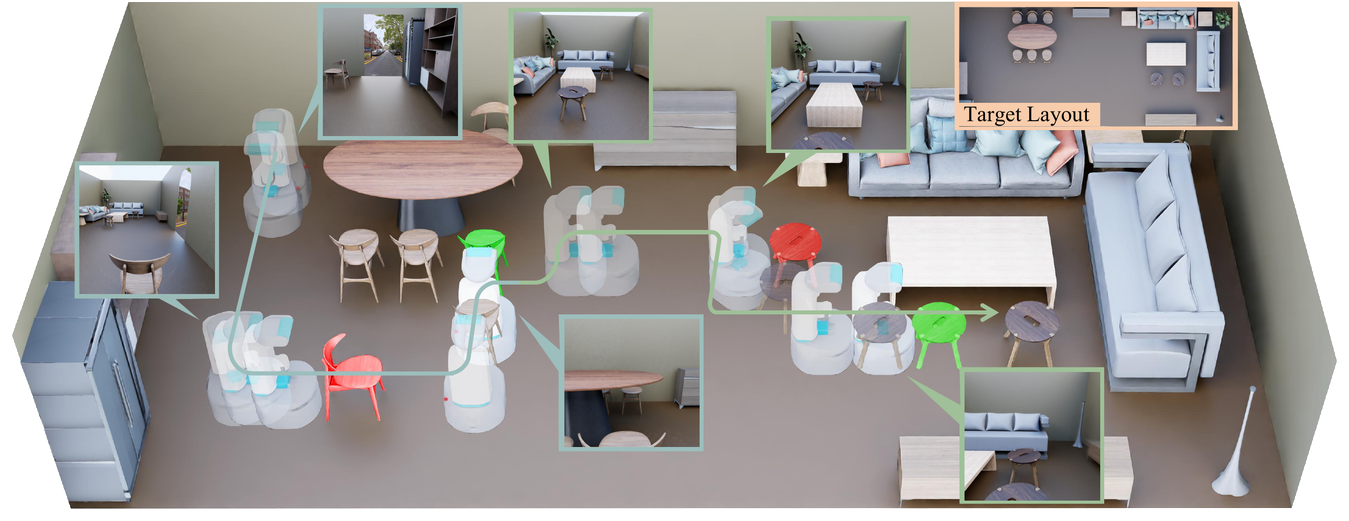
Embodied Scene Rearrangement Planning
Canzhi Chen*, Zan Wang*, Siqi Zhu*, Qi Wu*, Yixuan Li*, Wei Liang†
IEEE Robotics and Automation Letters (RA-L) 2026
ESRP introduces a benchmark and task that challenges robotic agents to move 3D indoor furniture from an initial setup to a target layout.
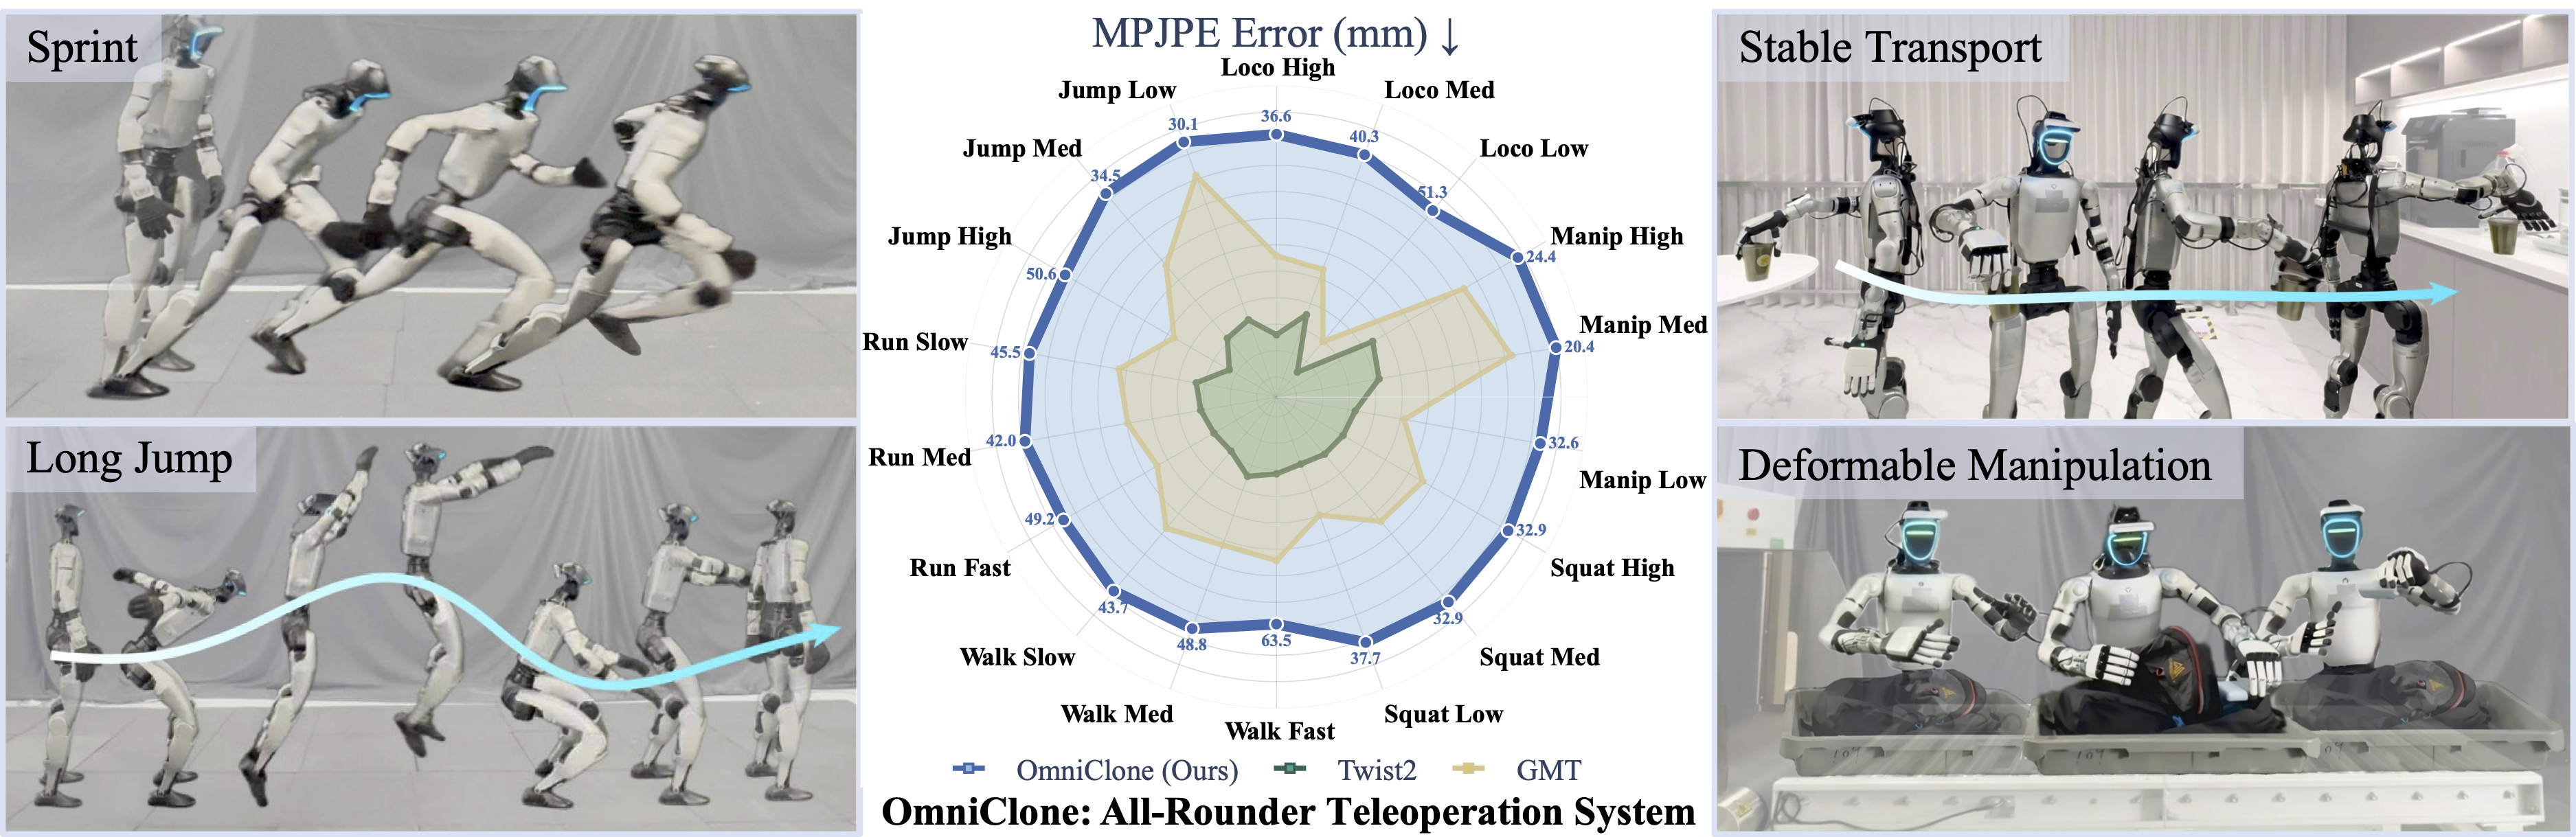
OmniClone: Engineering a Robust, All-RounderWhole-Body Humanoid Teleoperation System
Yixuan Li*, Le Ma*, Yutang Lin*, Yushi Du, Mengya Liu, Kaizhe Hu, Jieming Cui, Yixin Zhu†, Wei Liang†, Baoxiong Jia†, Siyuan Huang†
ArXiv 2026
OmniClone is a whole-body humanoid teleoperation system that achieves high-fidelity, multi-skill control on a single consumer GPU with modest data requirements.
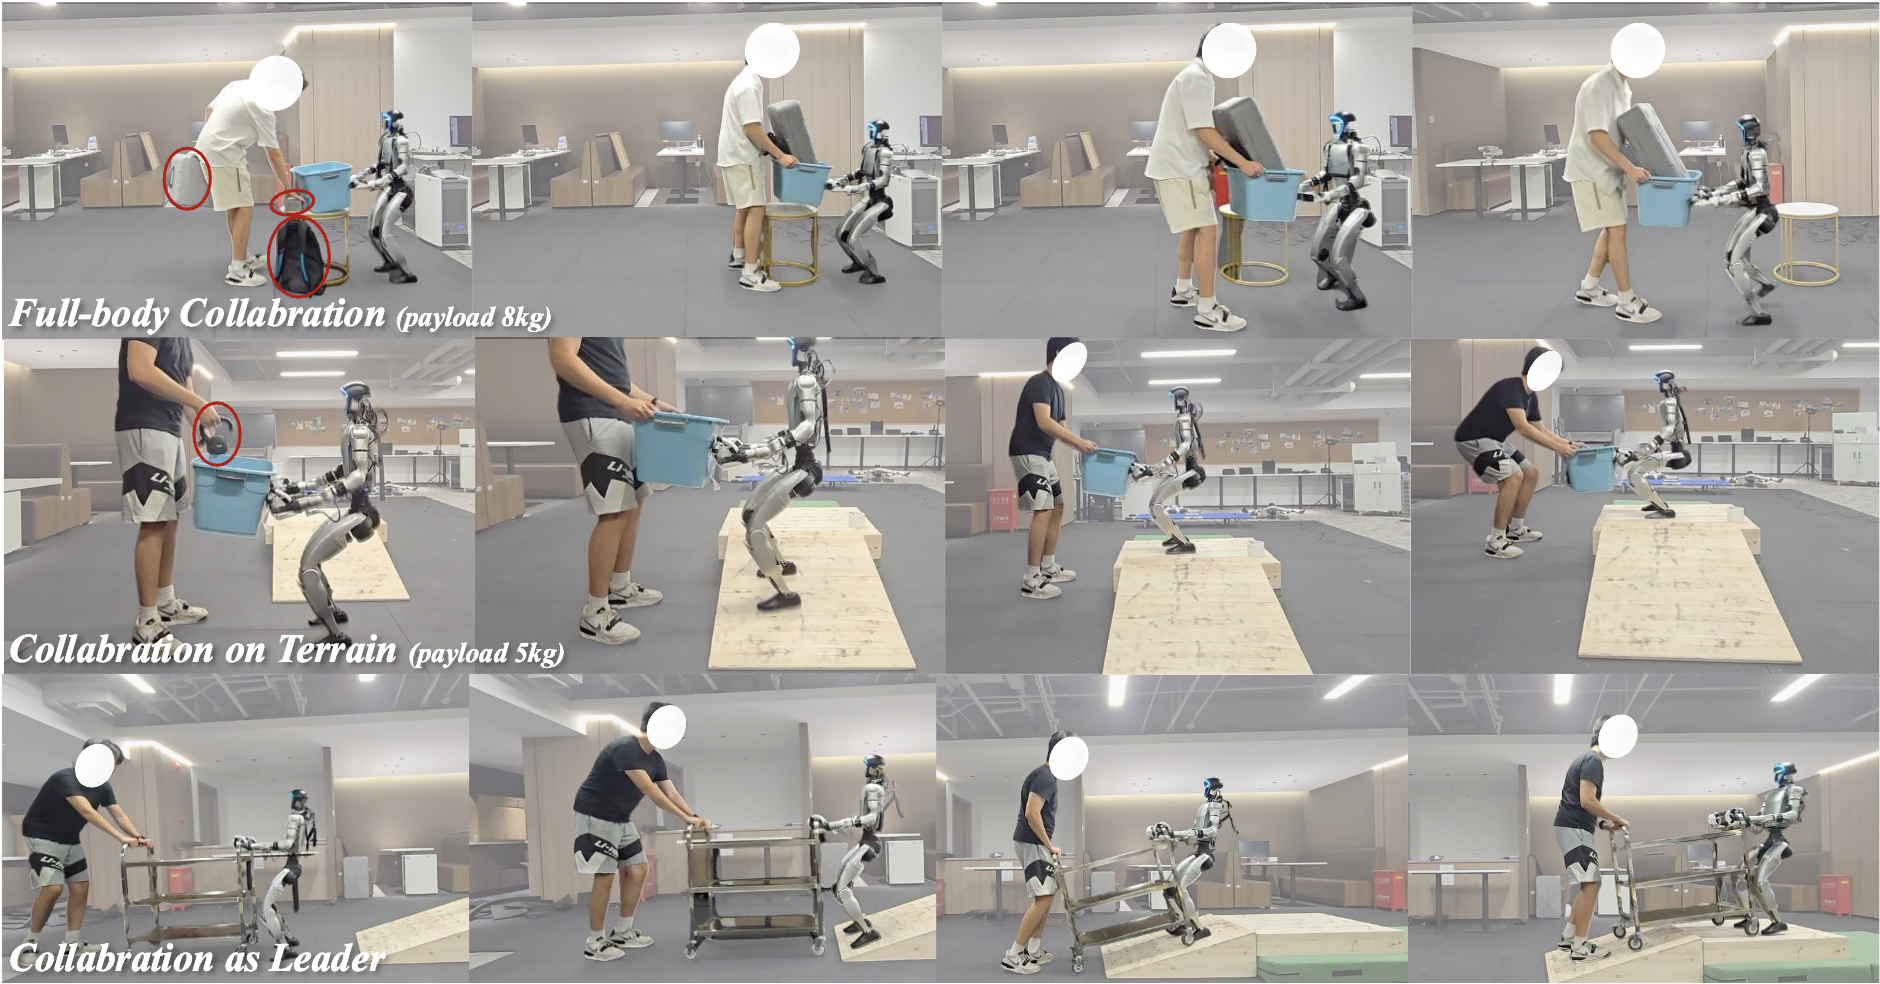
Learning Human-Humanoid Coordination for Collaborative Object Carrying
Yushi Du*, Yixuan Li*, Baoxiong Jia†*, Yutang Lin, Pei Zhou, Wei Liang†, Yanchao Yang†, Siyuan Huang†
International Conference on Robotics and Automation (ICRA) 2026
COLA is a proprioception-only reinforcement learning approach that combines leader and follower behaviors within a single policy, enabling compliant human-humanoid collaborative carrying.
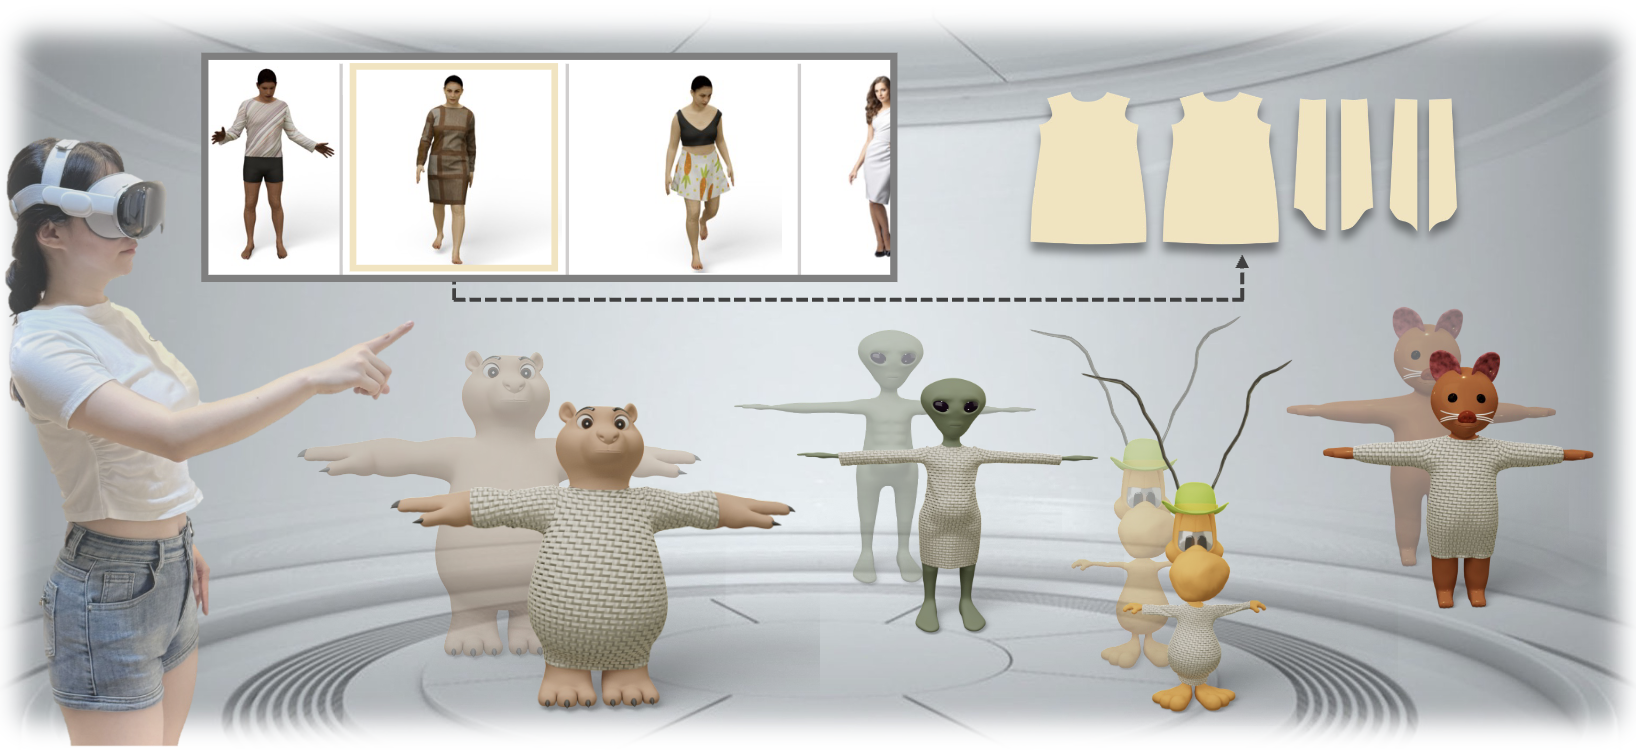
What You See Is What You Wear: Crafting Garments for Diverse Avatars with Consistent Wearing Effects.
Zan Wang*, Anqi Li*, Yixuan Li, Wei Liang†, Bing Ning
Transactions on Visualization and Computer Graphics (TVCG) 2026
Tailor is a two-stage framework that dresses 3D humanoid avatars from a single reference image while preserving the wearing effects observed in the image.
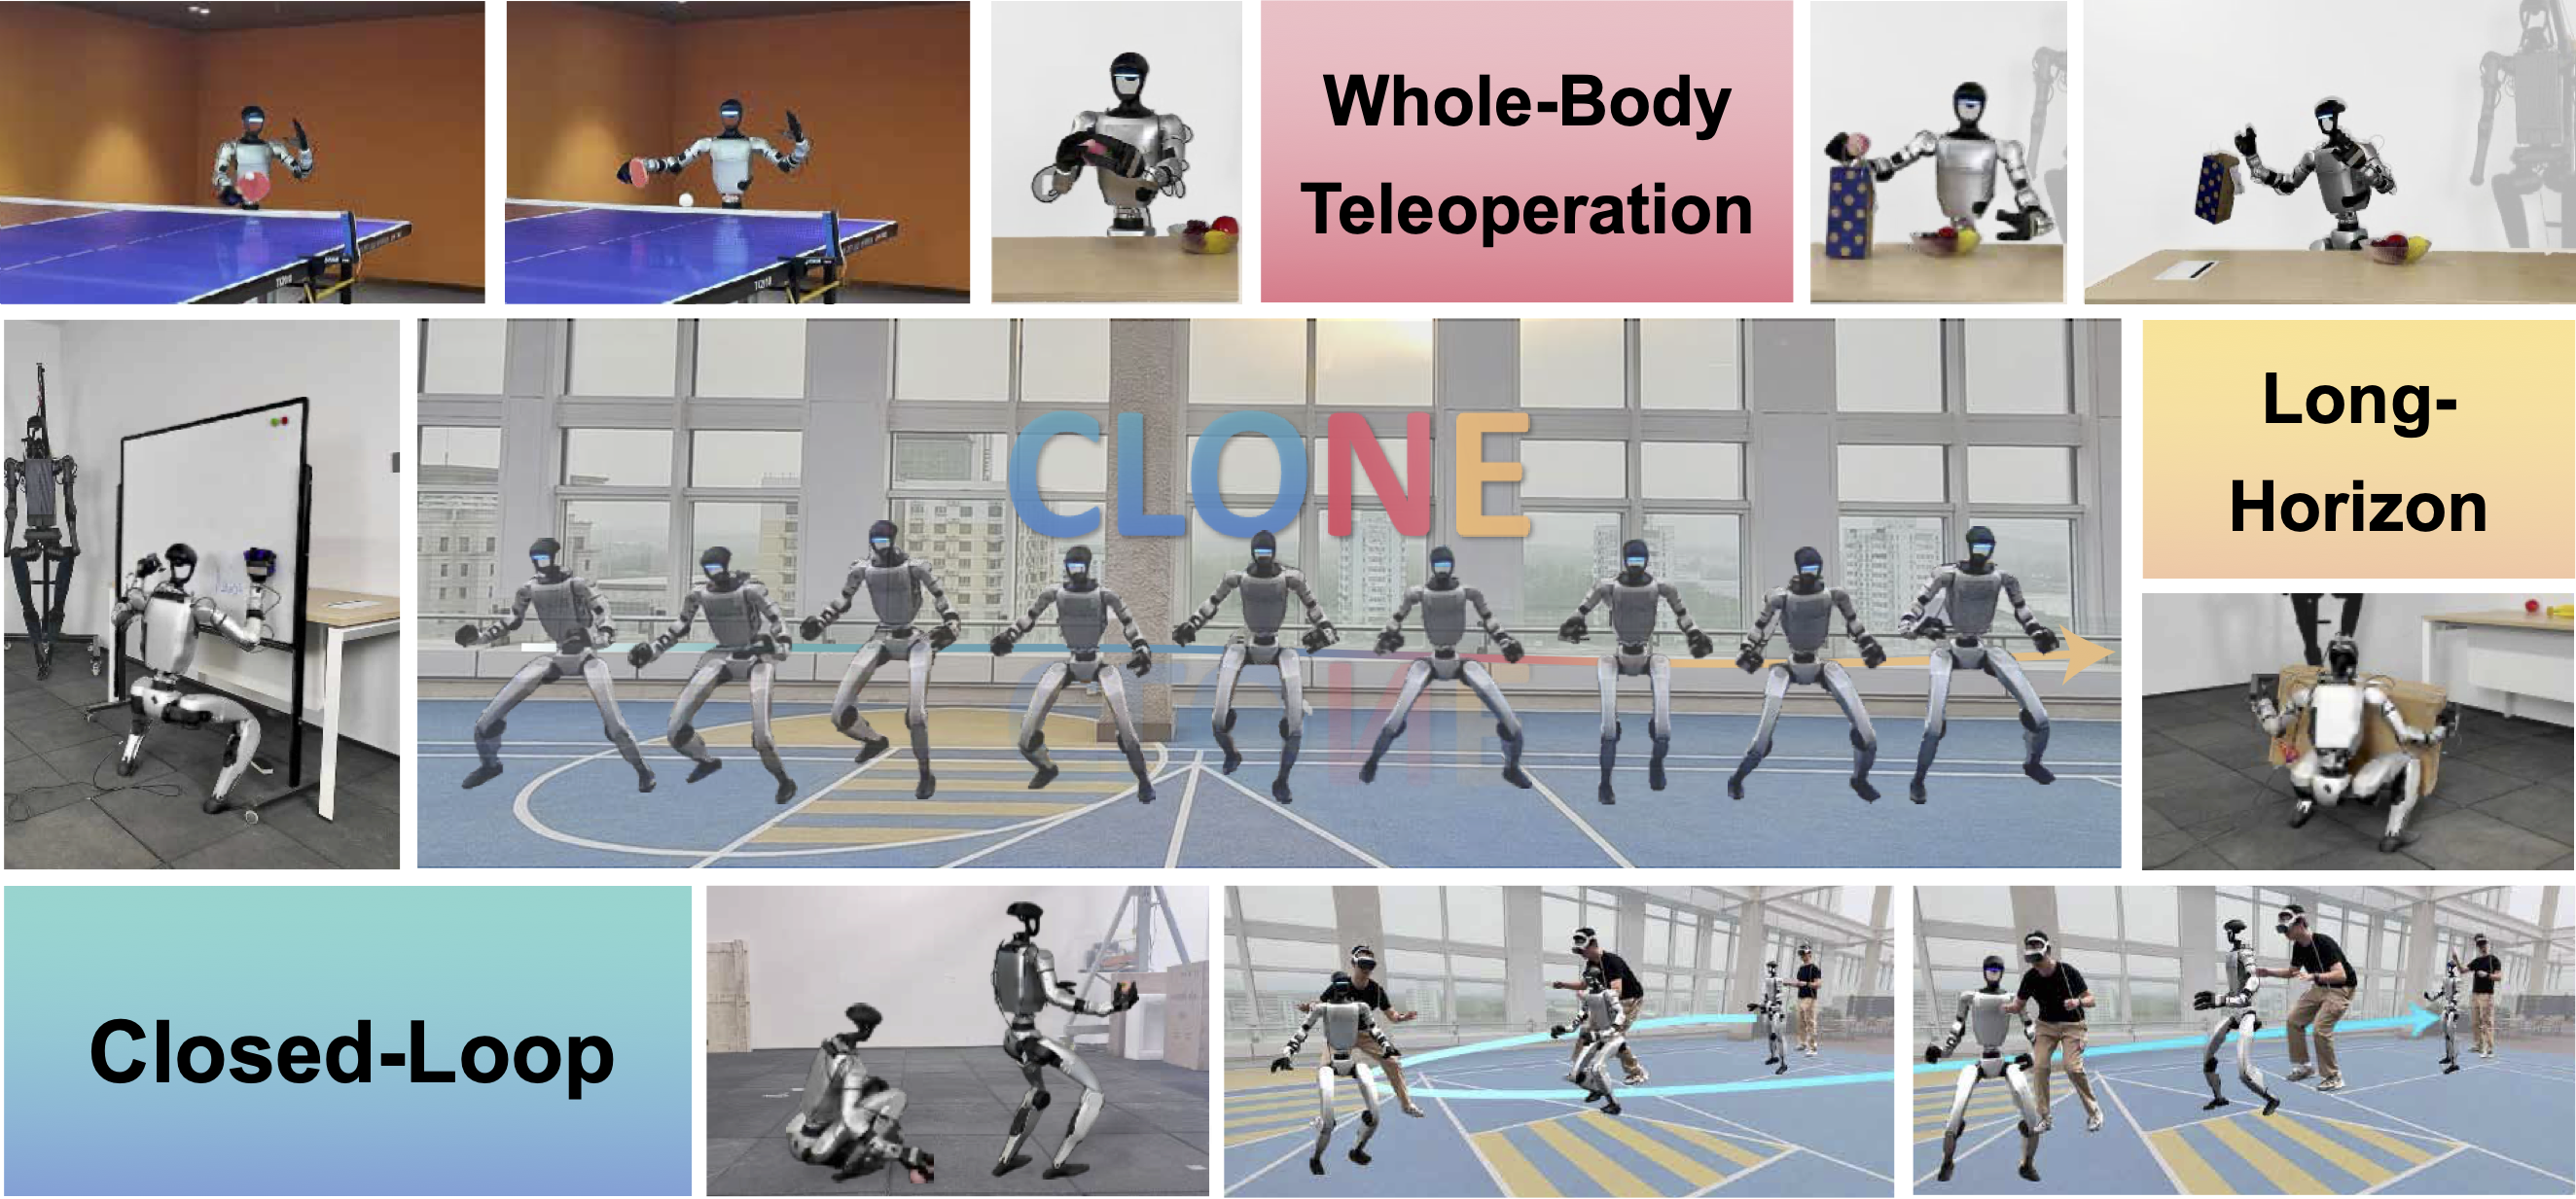
CLONE: Closed-Loop Whole-Body Humanoid Teleoperation for Long-Horizon Tasks
Yixuan Li*, Yutang Lin*, Jieming Cui, Tengyu Liu, Wei Liang†, Yixin Zhu†, Siyuan Huang†
Conference on Robot Learning (CoRL) 2025
CLONE is a whole-body teleoperation system that overcomes the limitations of decoupled upper- and lower-body control and open-loop execution.
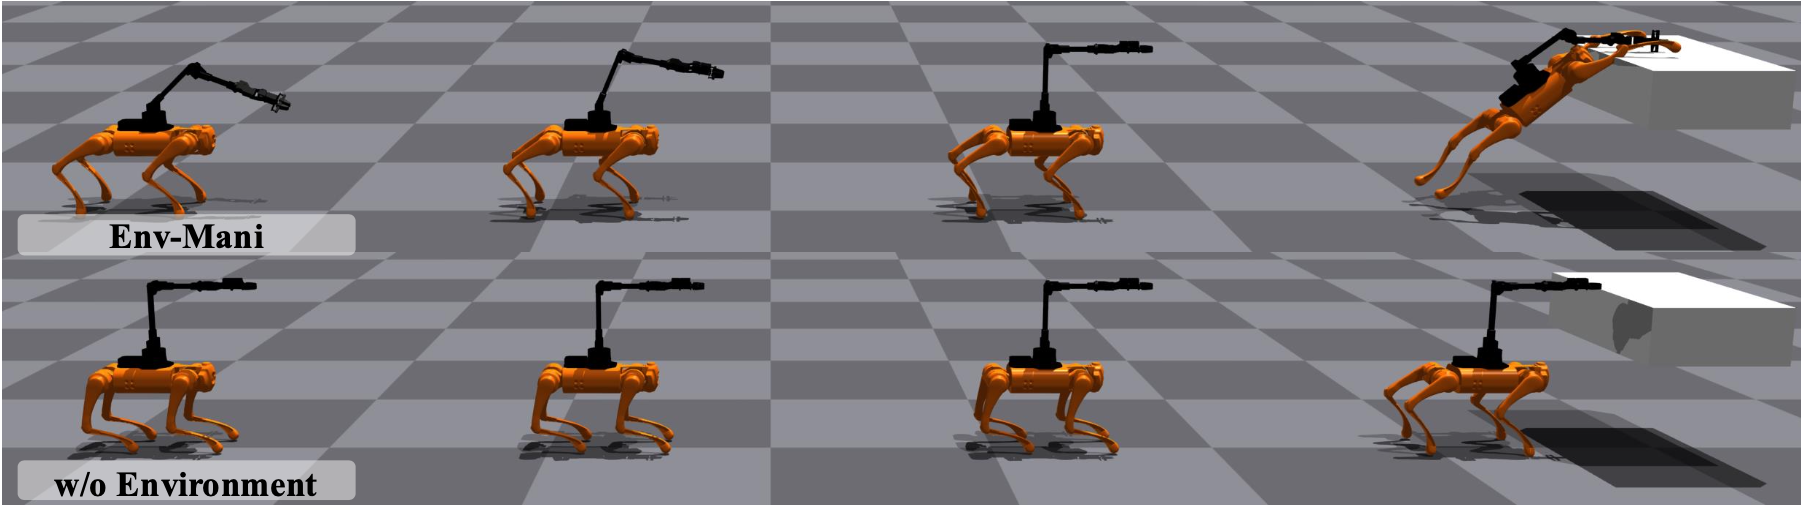
Env-Mani: Quadrupedal Robot Loco-Manipulation with Environment-in-the-Loop
Yixuan Li, Zan Wang, Wei Liang†
International Conference on Intelligent Robots and Systems (IROS) 2025
Env-Mani is a unified, learning-based loco-manipulation framework for quadrupedal robots that allows them to utilize the external environment as support to extend their workspace and enhance their manipulation capabilities.
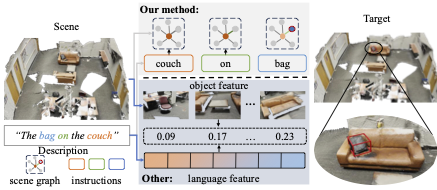
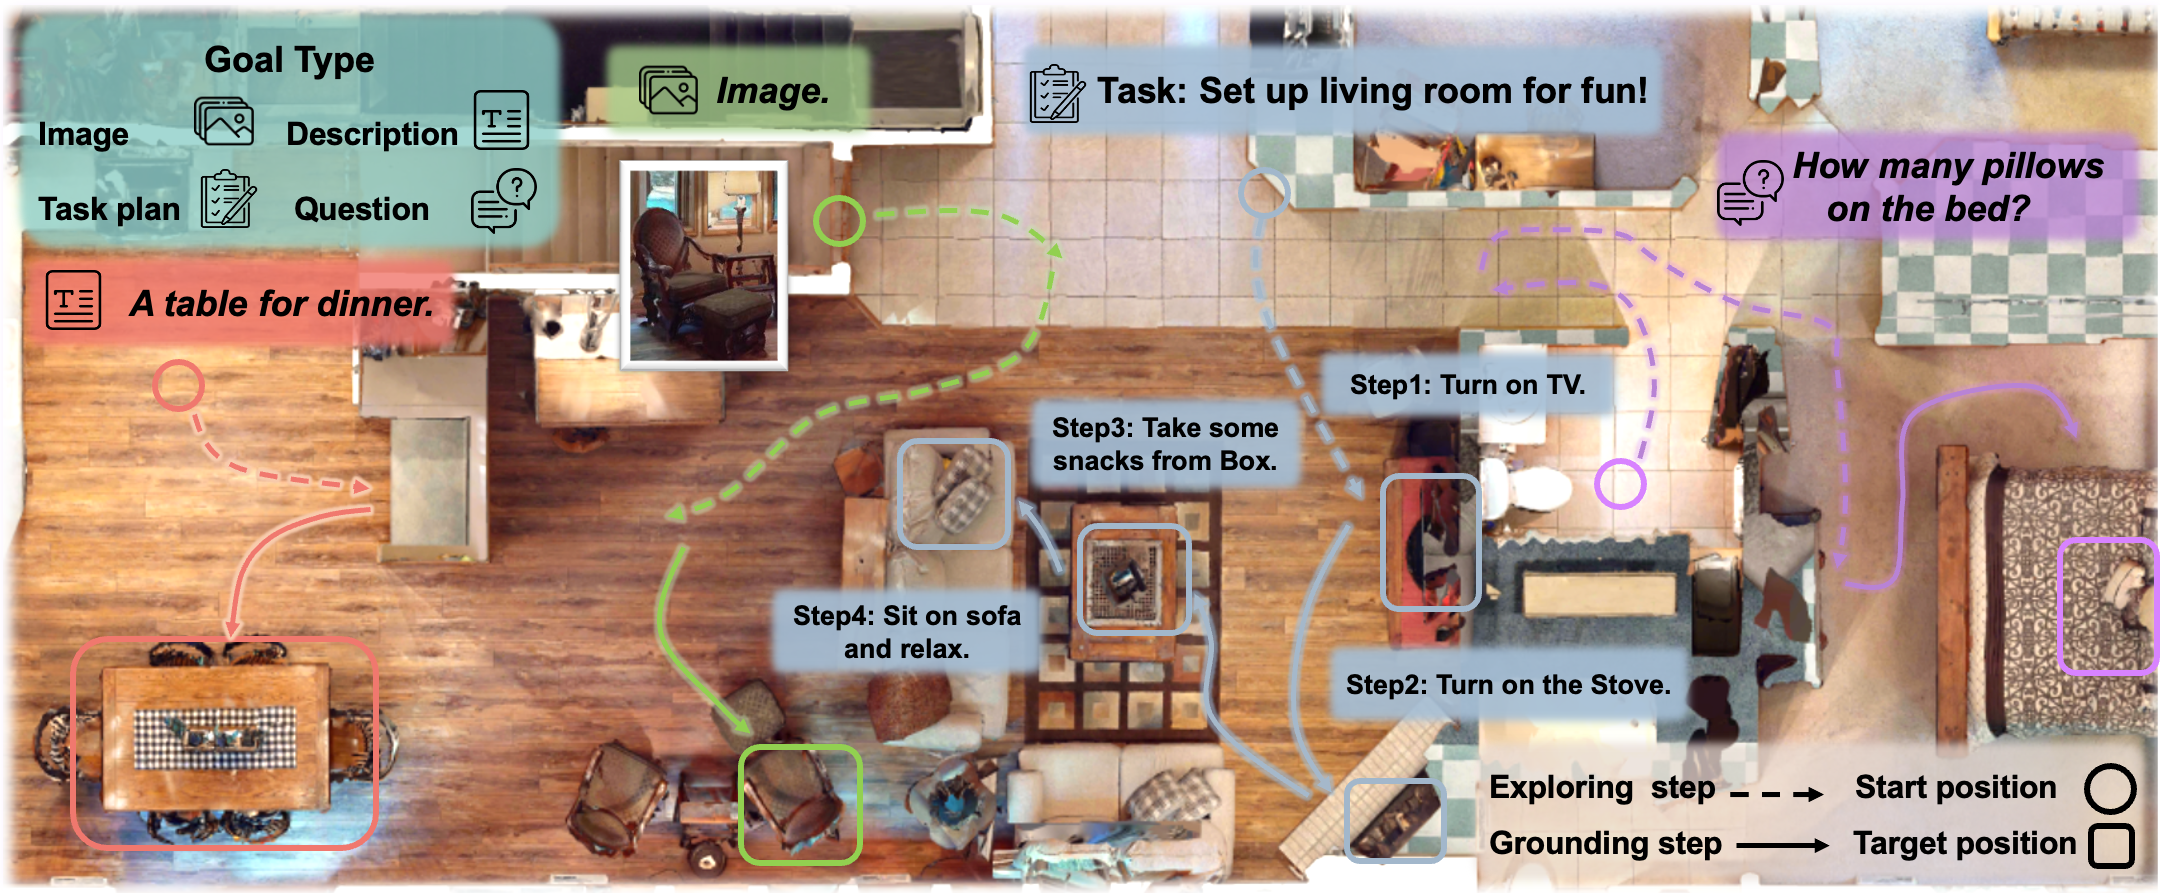
Move to Understand a 3D Scene: Bridging Visual Grounding and Exploration for Efficient and Versatile Embodied Navigation
Ziyu Zhu, Xilin Wang, Yixuan Li, Zhuofan Zhang, Xiaojian Ma, Yixin Chen, Baoxiong Jia, Wei Liang, Qian Yu, Zhidong Deng†, Siyuan Huang†, Qing Li†
International Conference on Computer Vision (ICCV) 2025
MTU3D is a unified framework that integrates active perception with 3D vision-language learning, enabling embodied agents to effectively explore and understand their environment.